ICRA '25
ReloPush: Multi-object Rearrangement in Confined Spaces with a Nonholonomic Mobile Robot Pusher
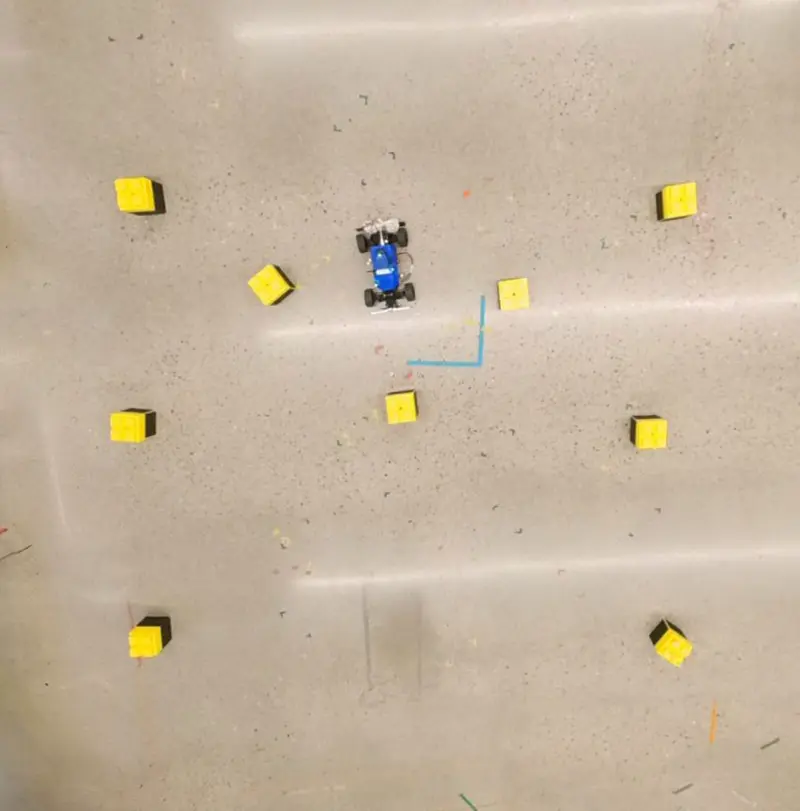
We developed ReloPush, a planning framework for rearranging multiple objects in cluttered spaces with a nonholonomic mobile robot pusher.
Video

BibTeX
@inproceedings{ahn2025relopush,
  title  = {ReloPush: Multi-object Rearrangement in Confined Spaces with a Nonholonomic Mobile Robot Pusher},
  author = {Jeeho Ahn and Christoforos Mavrogiannis},
  booktitle = {IEEE International Conference on Robotics and Automation (ICRA)},
  year   = {2025}
}