
IROS '20
Telemanipulation with chopsticks: Analyzing human factors in user demonstrations
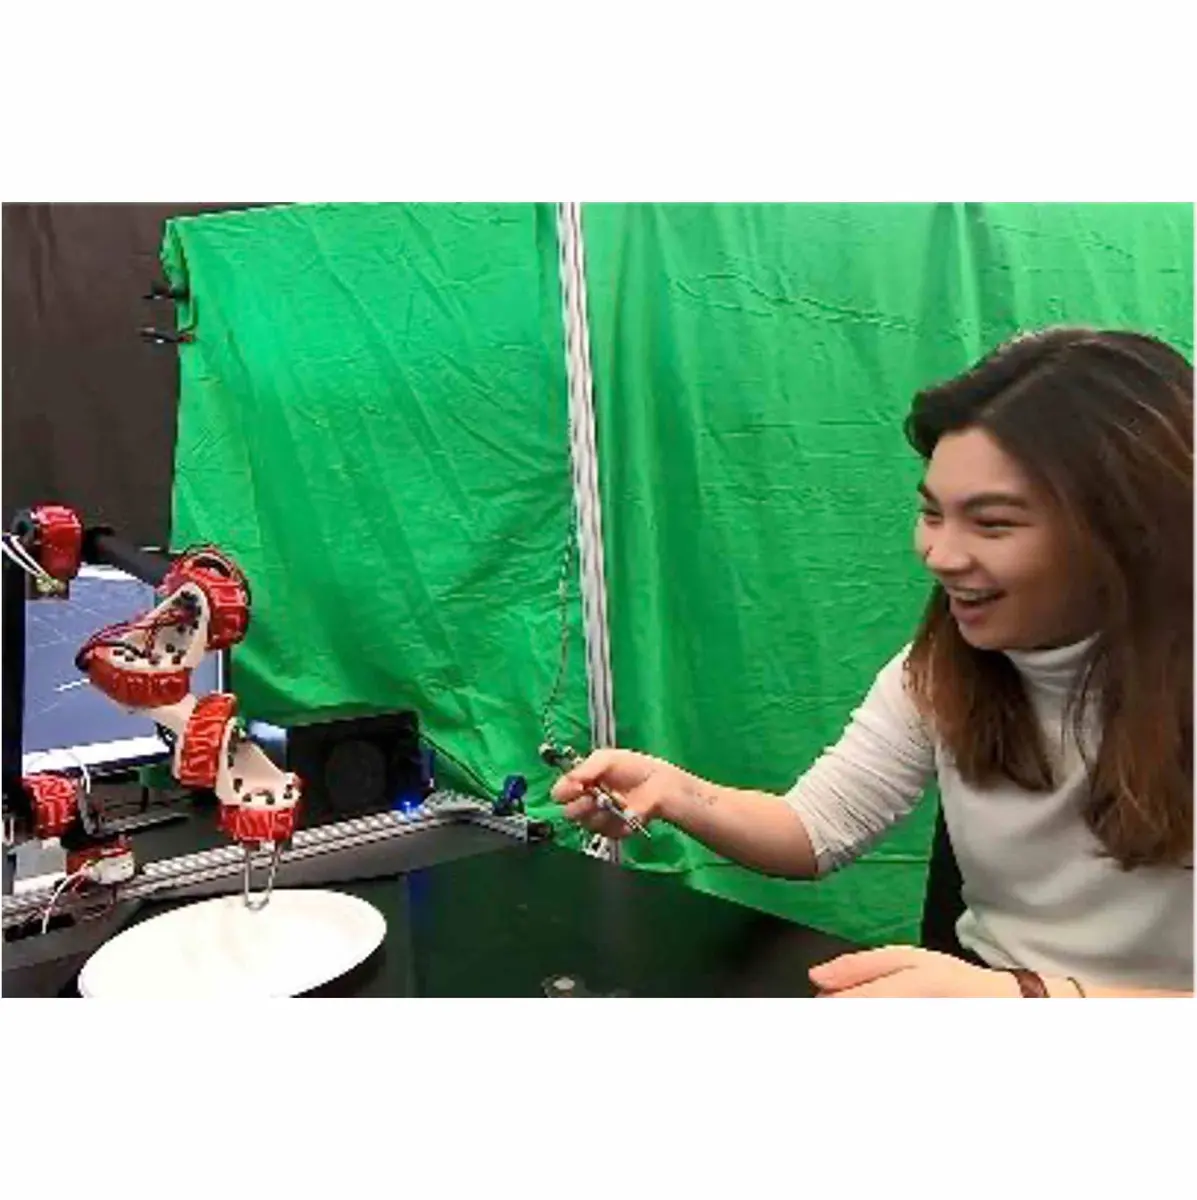
We developed a new system for chopsticks-based telemanipulation and conducted a user study (N=25) to gain insights into human manipulation strategies. We show that our system enables novice users to complete a series of challenging grasping tasks.
Video

BibTeX
@inproceedings{ke2020chopsticks,
  title  = {Telemanipulation with chopsticks: Analyzing human factors in user demonstrations},
  author = {Liyiming Ke and Ajinkya Kamat and Jingqiang Wang and Tapomayukh Bhattacharjee and Christoforos Mavrogiannis and Siddhartha S Srinivasa},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year   = {2020}
}Lab members