
HRI '17
Implicit communication in a joint action
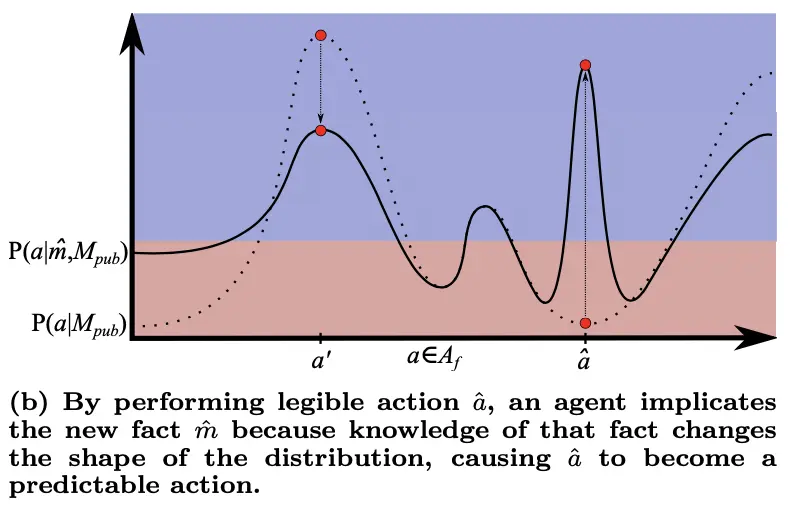
We formalize a general framework that enables robots to encode communicative signals on their actions to seamlessly convey information to their human partners on top of accomplishing the functional objectives of a task. We show how the framework maps onto various modalities, including natural language and motion.
BibTeX
@inproceedings{knepper2017implicit,
  title  = {Implicit communication in a joint action},
  author = {Ross Knepper and Christoforos Mavrogiannis and Julia Proft and Claire Liang},
  booktitle = {ACM/IEEE International Conference on Human-Robot Interaction (HRI)},
  year   = {2017}
}Lab members