
IROS '15
Open-source, anthropomorphic, underactuated robot hands with a selectively lockable differential mechanism: Towards affordable prostheses
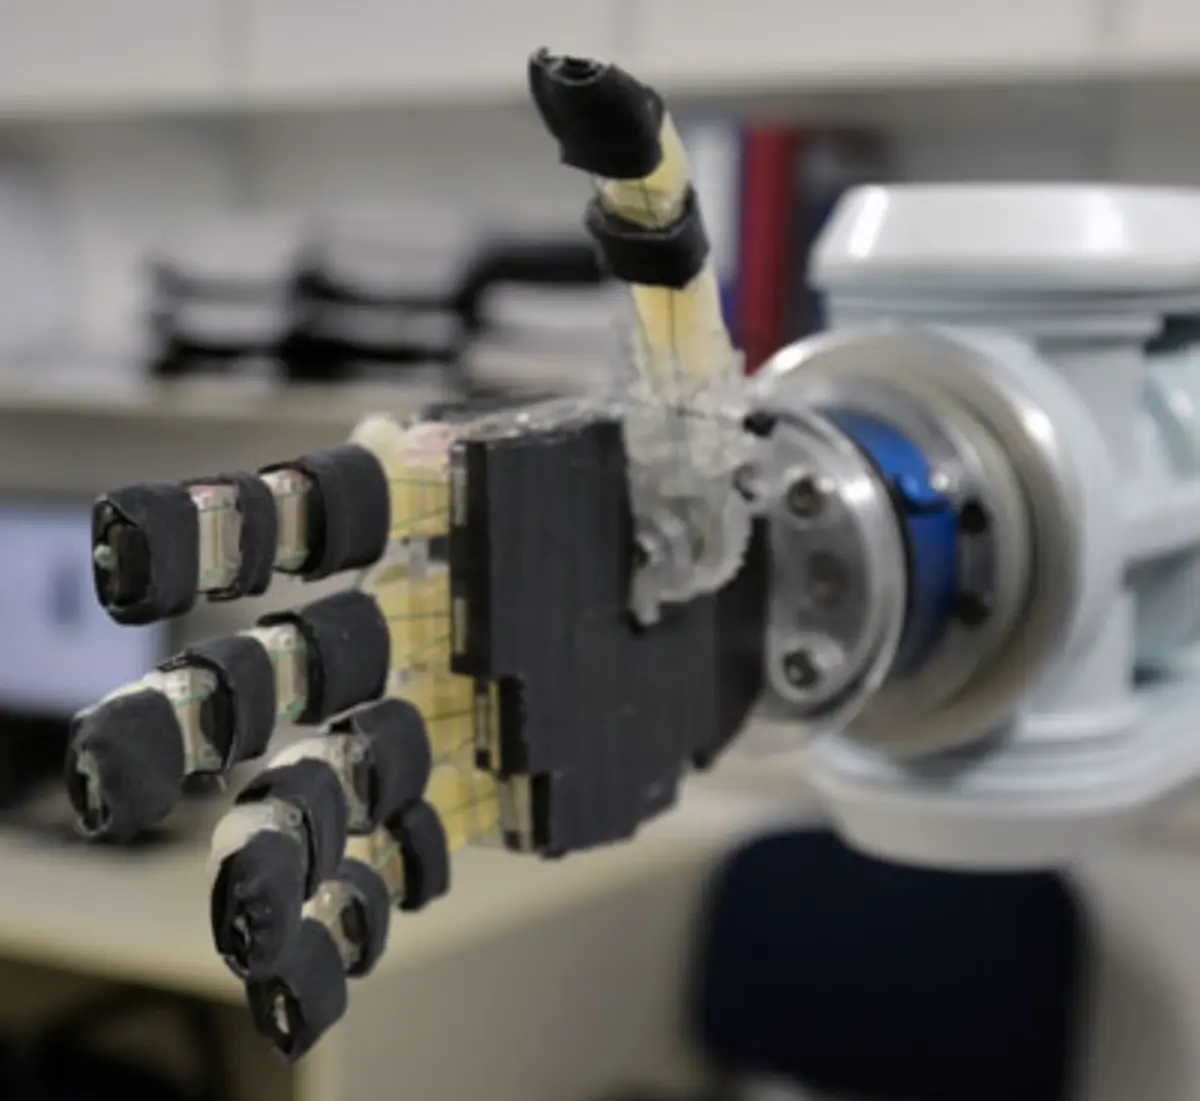
We present a new, open-source mechanical hand, designed according to human anthropometry studies to support the development of low-cost prosthetics. The hand can be assembled using off-the-shelf components and parts fabricated via standard prototyping techniques.
BibTeX
@inproceedings{kontoudis2015prosthetic,
  title  = {Open-source, anthropomorphic, underactuated robot hands with a selectively lockable differential mechanism: Towards affordable prostheses},
  author = {George Kontoudis and Minas Liarokapis and Agisilaos Zisimatos and Christoforos Mavrogiannis and Kostas Kyriakopoulos},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year   = {2015}
}Lab members