
IROS '22
Optical proximity sensing for pose estimation during in-hand manipulation
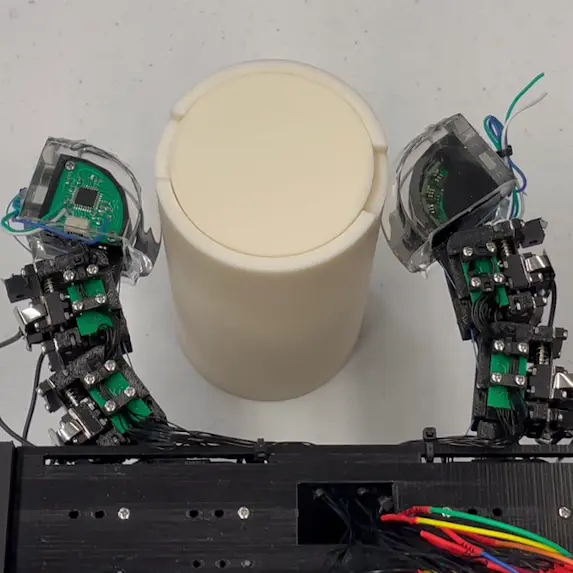
We developed a new gripper with optical proximity sensing on fingertips. We demonstrate that proximity sensing enables significantly more accurate object pose estimation during manipulation compared to tactile sensing.
Video

BibTeX
@inproceedings{lancaster2022optical,
  title  = {Optical proximity sensing for pose estimation during in-hand manipulation},
  author = {Patrick Lancaster and Pratik Gyawali and Christoforos Mavrogiannis and Siddhartha Srinivasa and Joshua Smith},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year   = {2022}
}Lab members