
IJRR '24
Electrostatic brakes enable individual joint control of underactuated, highly articulated robots
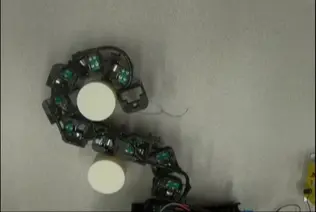
We developed a lightweight, power-efficient mechanism based on electrostatic-braking technology. Using only 1 motor, our mechanism enabled a 10-DoF manipulator to perform a complex multi-object manipulation task.
Video

BibTeX
@article{lancaster2024brakes,
  title  = {Electrostatic brakes enable individual joint control of underactuated, highly articulated robots},
  author = {Patrick Lancaster and Christoforos Mavrogiannis and Siddhartha Srinivasa and Joshua Smith},
  journal = {The International Journal of Robotics Research},
  year   = {2024}
}Lab members