
ICRA '13
Sequential improvement of grasp based on sensitivity analysis
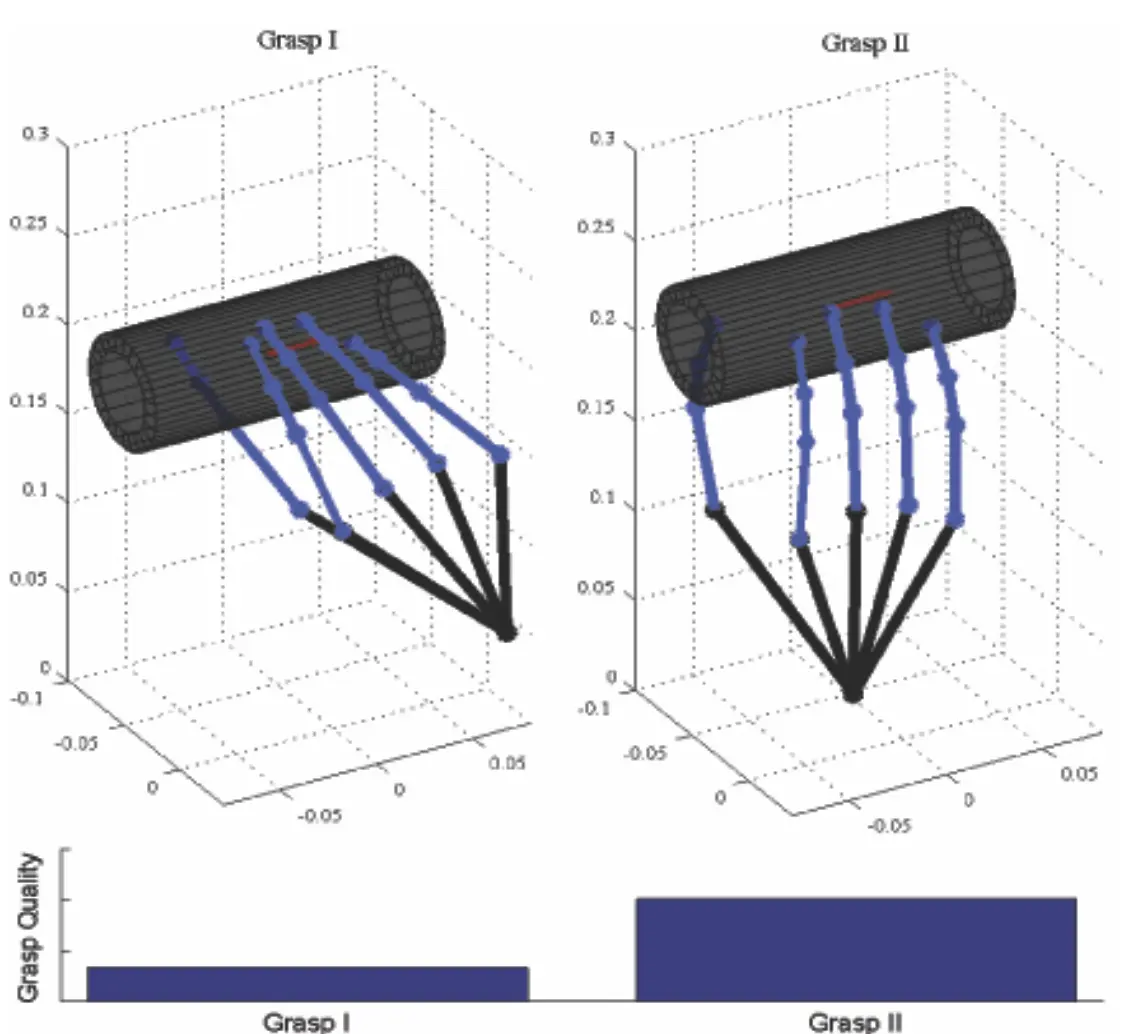
We present an algorithm that takes as input a locally optimal robot grasp and outputs a grasp of higher quality by sequentially perturbing the hand posture and force exertion via sensitivity analysis. Simulations on the DLR/HIT Hand II demonstrate the value of the approach.
BibTeX
@inproceedings{mavrogiannis2013sequential,
  title  = {Sequential improvement of grasp based on sensitivity analysis},
  author = {Christoforos Mavrogiannis and Charalampos Bechlioulis and Kostas Kyriakopoulos},
  booktitle = {IEEE International Conference on Robotics and Automation (ICRA)},
  year   = {2013}
}Lab members