
IROS '15
Quantifying anthropomorphism of robot arms
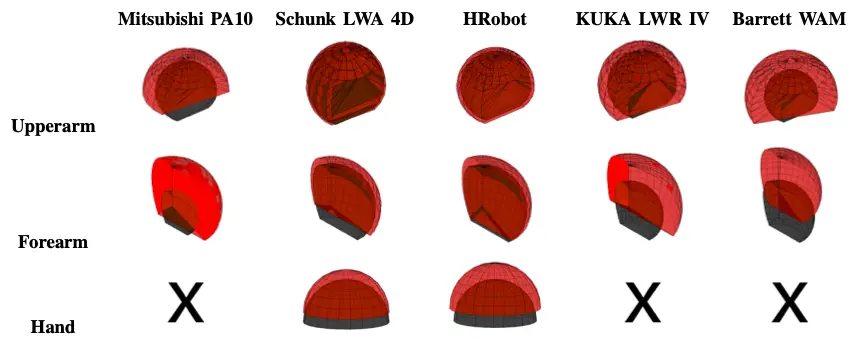
We introduce an index for assessing the anthropomorphism of a robot manipulator by comparing its workspace to the workspace of a human arm. A case study on commercial manipulators demonstrates the value of the approach.
BibTeX
@inproceedings{mavrogiannis2015anthropomorphism,
  title  = {Quantifying anthropomorphism of robot arms},
  author = {Christoforos Mavrogiannis and Minas Liarokapis and Kostas Kyriakopoulos},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year   = {2015}
}Lab members