
ICRA '22
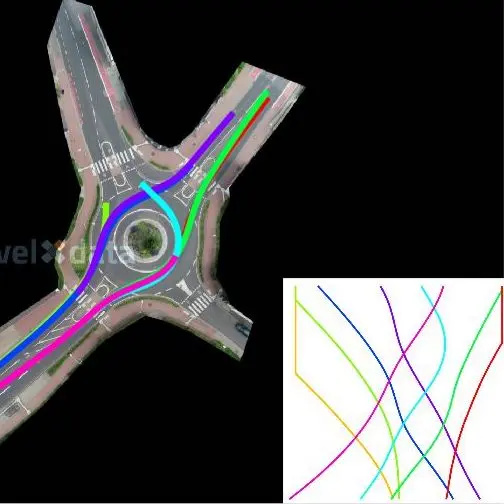
Analyzing multiagent interactions in traffic scenes via topological braids
We show that topological braids can be used as a tool to characterize the interactivity of vehicles, which can be useful for evaluating the richness of existing datasets, but also for synthetically designing balanced training datasets and benchmarks.
Video

BibTeX
@inproceedings{mavrogiannis2022analyzing,
  title  = {Analyzing multiagent interactions in traffic scenes via topological braids},
  author = {Christoforos Mavrogiannis and Jonathan DeCastro and Siddhartha Srinivasa},
  booktitle = {IEEE International Conference on Robotics and Automation (ICRA)},
  year   = {2022}
}Lab members