
RA-L '23
Winding through: Crowd navigation via topological invariance
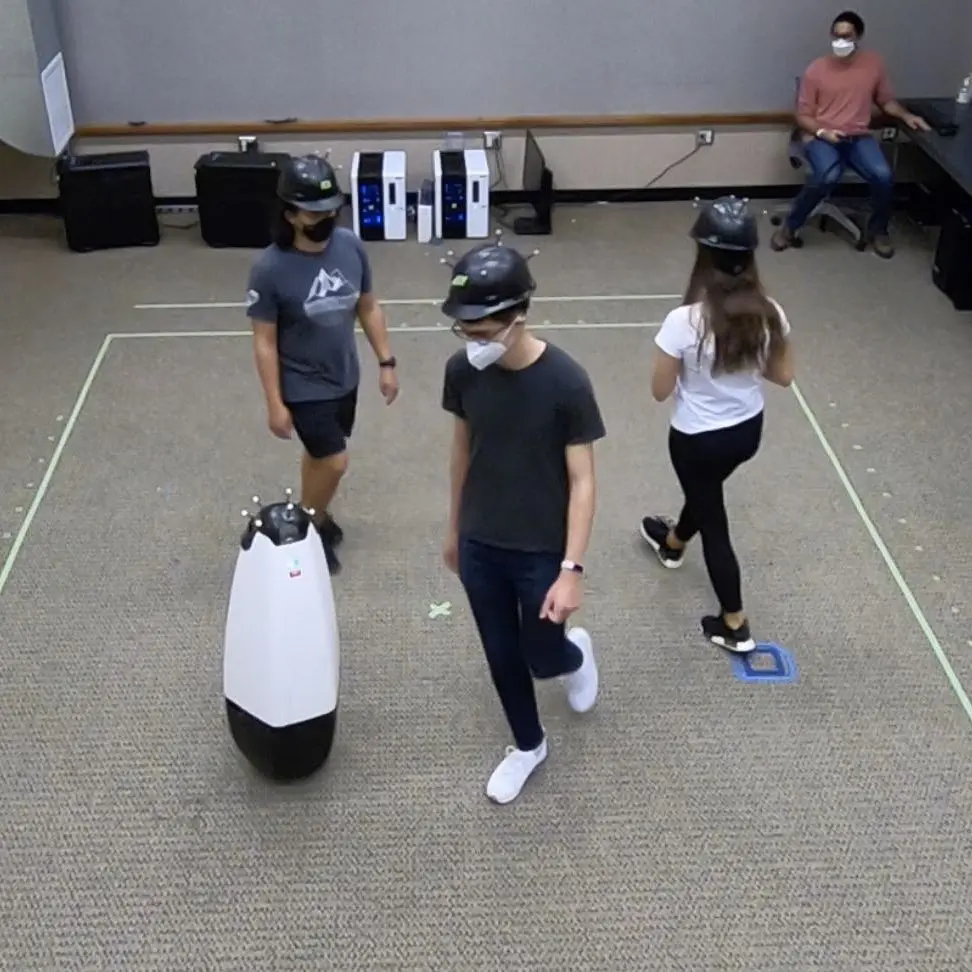
We formalize passing between two agents as a rotation, using a notion of topological invariance, and build a MPC that expedites passing progress in crowded spaces. We demonstrate our approach on a self-balancing robot navigating among 3 users in a lab experiment.
Video

BibTeX
@article{mavrogiannis2023winding,
  title  = {Winding through: Crowd navigation via topological invariance},
  author = {Christoforos Mavrogiannis and Krishna Balasubramanian and Sriyash Poddar and Anush Gandra and Siddhartha Srinivasa},
  journal = {IEEE Robotics and Automation Letters},
  year   = {2023}
}Lab members