
RSS '24
Demonstrating HOUND: A Low-cost Research Platform for High-speed Off-road Underactuated Nonholonomic Driving
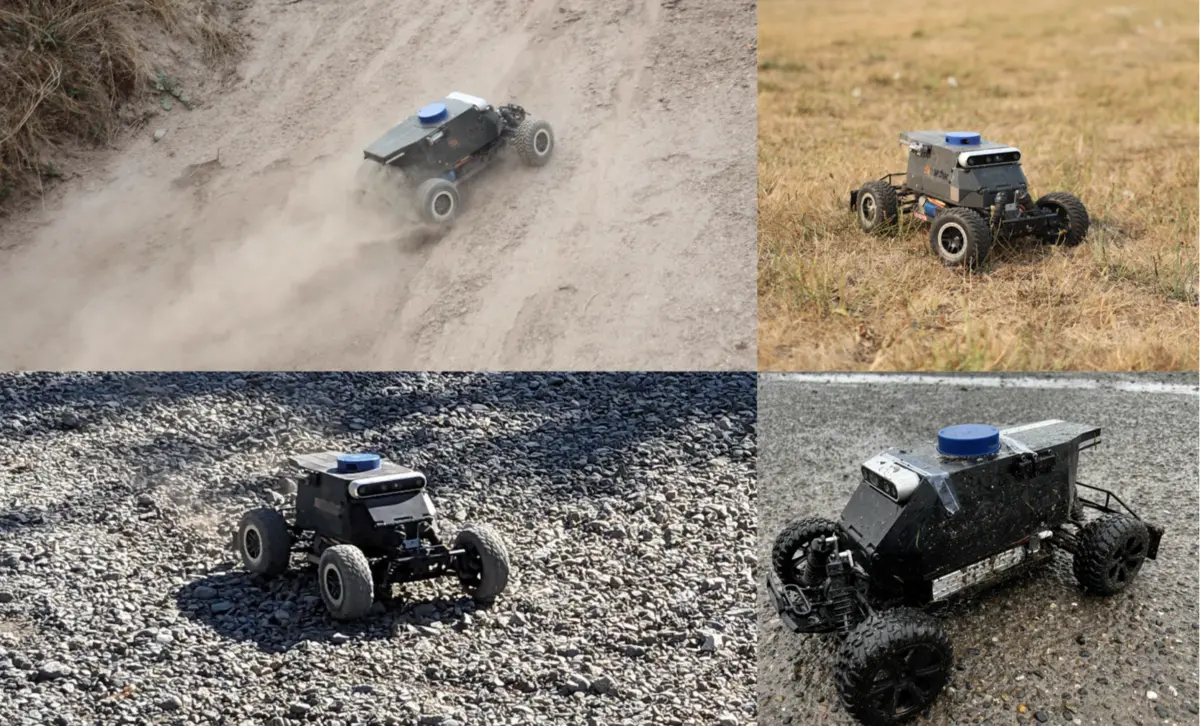
We present HOUND, a small-scale, inexpensive, off-road autonomy platform that handles challenging off-road terrains at high speeds through the integration of a rollover prevention system. HOUND is integrated with a complete stack for perception and control.
BibTeX
@inproceedings{talia2024hound,
  title  = {Demonstrating HOUND: A Low-cost Research Platform for High-speed Off-road Underactuated Nonholonomic Driving},
  author = {Sidharth Talia and Matt Schmittle and Alexander Lambert and Alexander Spitzer and Christoforos Mavrogiannis and Siddhartha S. Srinivasa},
  booktitle = {Robotics: Science and Systems (RSS)},
  year   = {2024}
}Lab members