
CoRL '21
Influencing behavioral attributions to robot motion during task execution
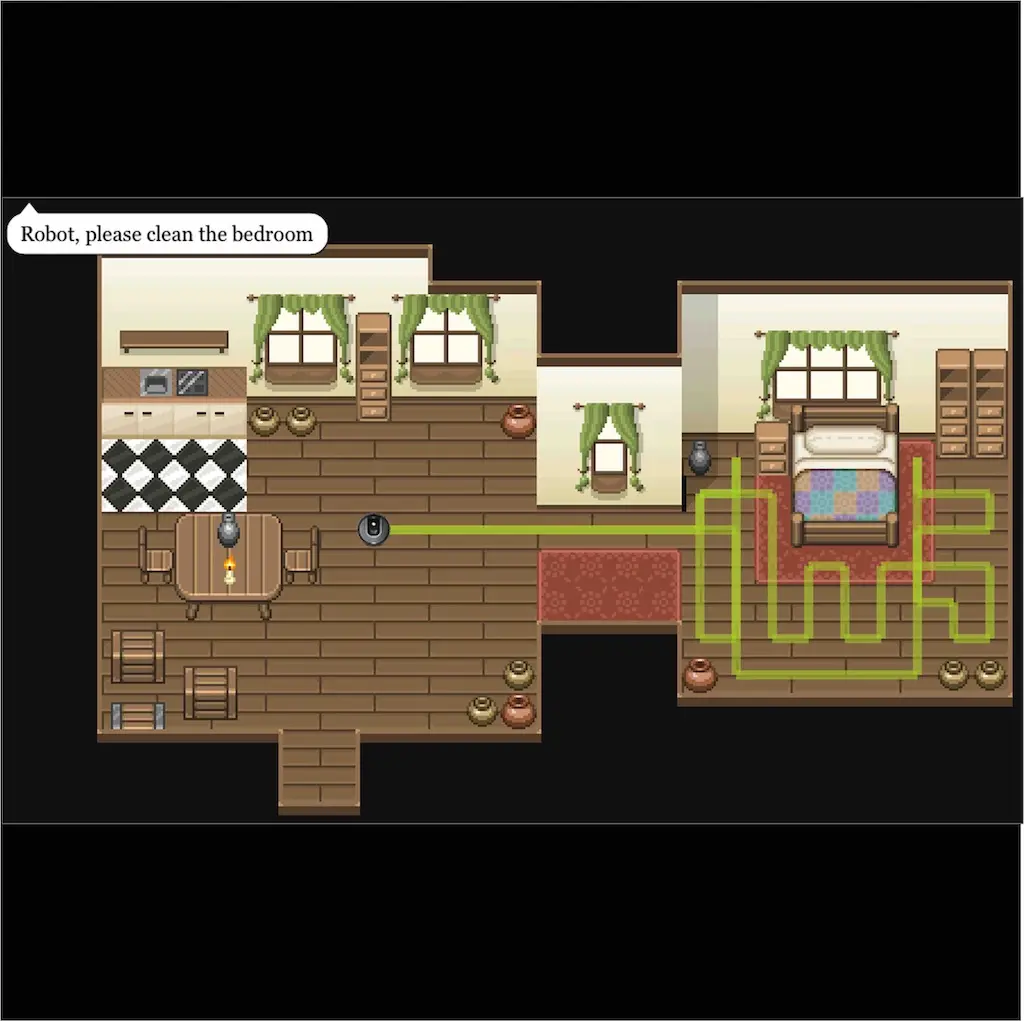
We propose a framework that probabilistically maps robot motion to user attributions and use it to generate robot motion that elicits desired attributions while completing a robot vacuum cleaning task.
BibTeX
@inproceedings{walker2021attributions,
  title  = {Influencing behavioral attributions to robot motion during task execution},
  author = {Nick Walker and Christoforos Mavrogiannis and Siddhartha Srinivasa and Maya Cakmak},
  booktitle = {Proceedings of the Conference on Robot Learning (CoRL)},
  year   = {2021}
}Lab members