
CoRL '21
Group-based motion prediction for navigation in crowded environments
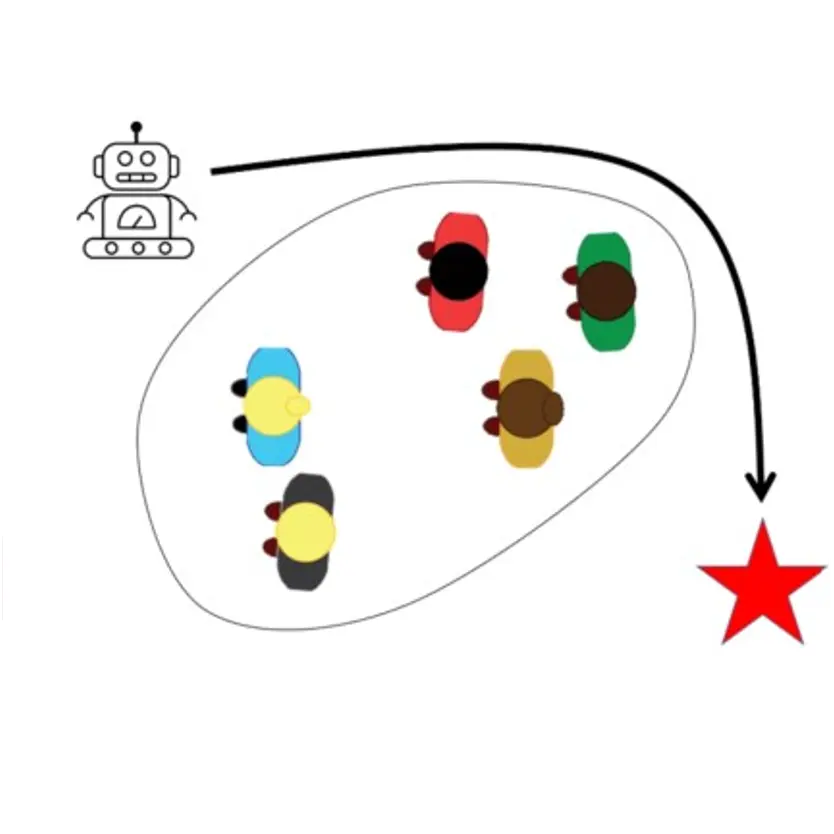
Inspired by Gestalt theories from psychology, we build a group-based prediction model and integrate it into a MPC, demonstrating higher safety and fewer group intrusions compared to baselines using individual motion prediction across extensive simulations and real-world pedestrian datasets.
BibTeX
@inproceedings{wang2021group,
  title  = {Group-based motion prediction for navigation in crowded environments},
  author = {Allan Wang and Christoforos Mavrogiannis and Aaron Steinfeld},
  booktitle = {Proceedings of the Conference on Robot Learning (CoRL)},
  year   = {2021}
}Lab members