
IROS '14
Open-Source, Affordable, Modular, Light-Weight, Underactuated Robot Hands
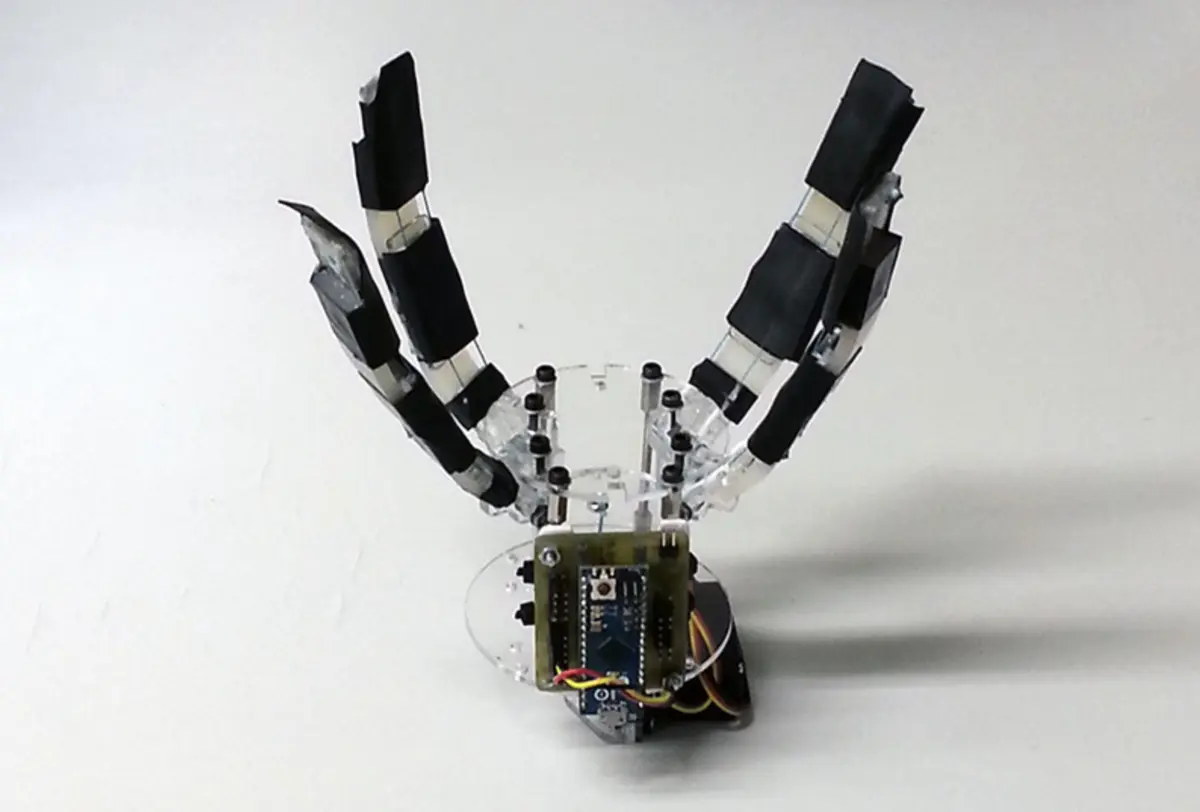
We present a new underactuated robot hand that can be built using off-the-shelf components, and easily fabricated parts. Real-world experiments demonstrate the promise of the design for grasping a wide range of everyday-life objects.
BibTeX
@inproceedings{zisimatos2014robothands,
  title  = {Open-Source, Affordable, Modular, Light-Weight, Underactuated Robot Hands},
  author = {Agisilaos Zisimatos and Minas Liarokapis and Christoforos Mavrogiannis and Kostas Kyriakopoulos},
  booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year   = {2014}
}Lab members