
IJRR '19 (WAFR 2016 special issue)
Multi-agent path topology in support of socially competent navigation planning
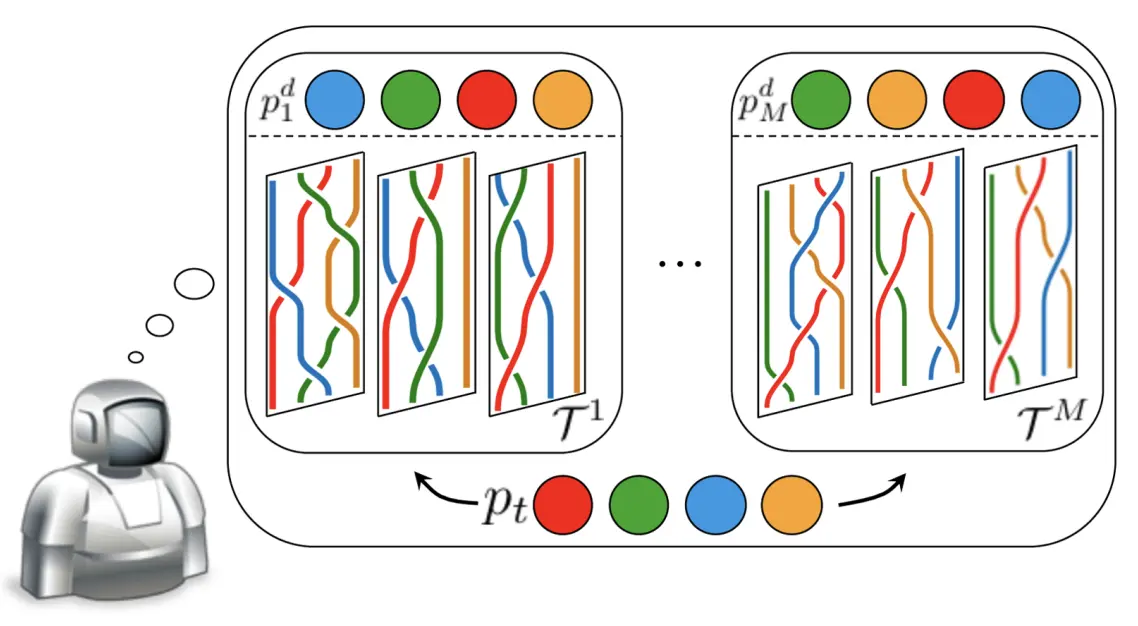
We introduce the idea of using topological braids as representatives of coordination strategies braids in multiagent navigation domains. Simulated experiments in a gridworld show that agents reasoning about braids may coordinate efficiently without relying on explicit communication.
Video

BibTeX
@article{mavrogiannis2019topology,
  title  = {Multi-agent path topology in support of socially competent navigation planning},
  author = {Christoforos Mavrogiannis and Ross Knepper},
  journal = {The International Journal of Robotics Research, WAFR 2016 special issue},
  year   = {2019}
}Lab members