
T-HRI '22
Social Momentum: Design and evaluation of a framework for socially competent robot navigation
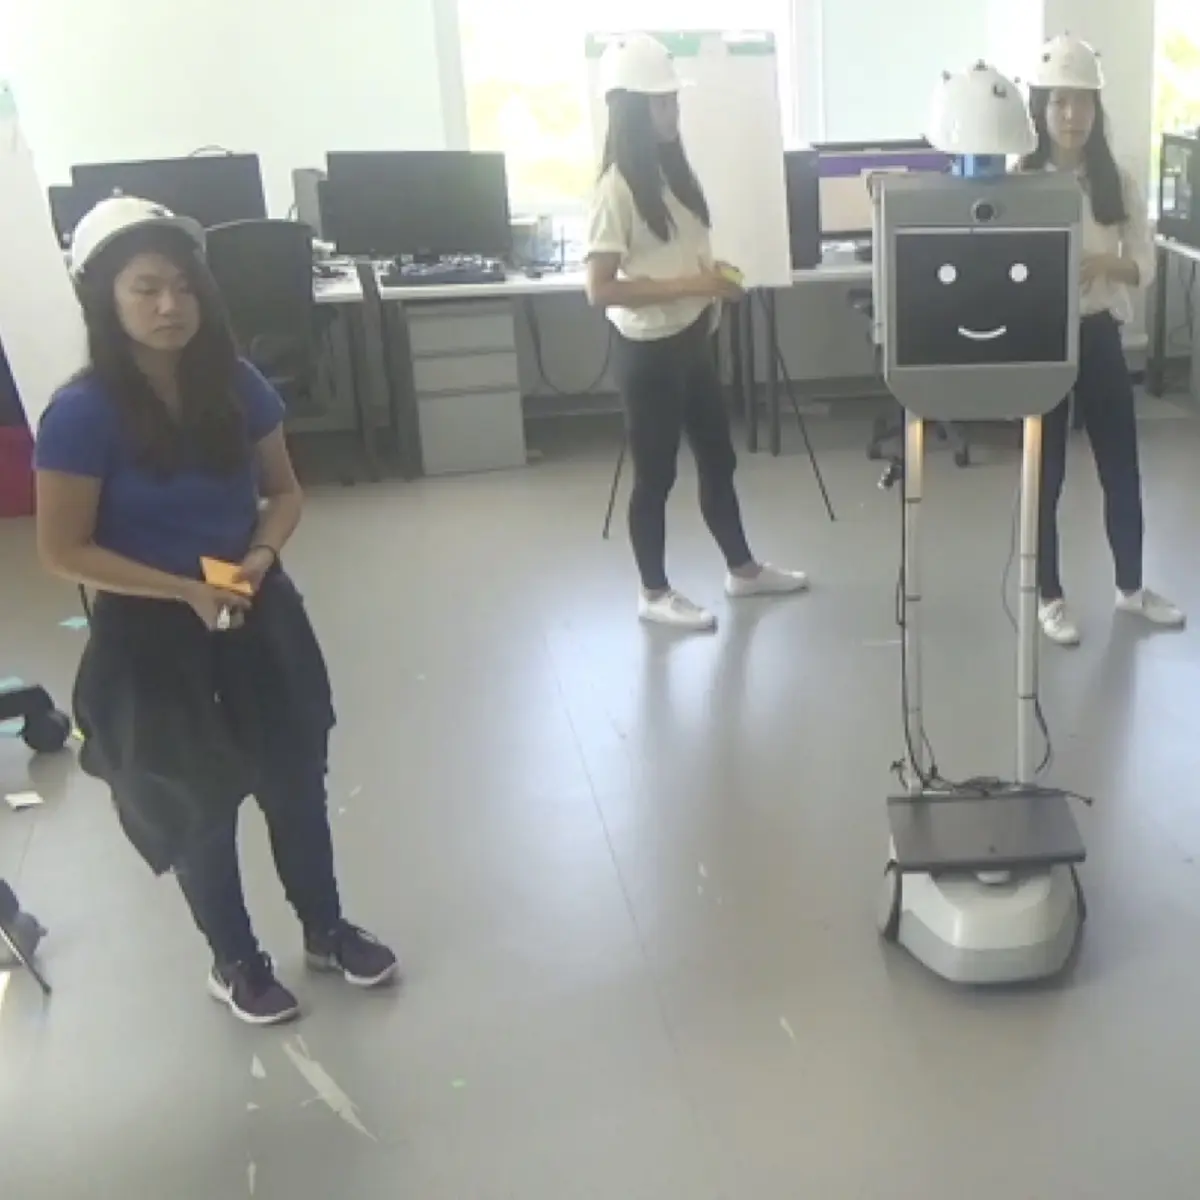
We summarize our findings from two large-scale user studies evaluating Social Momentum, a reactive controller for robot crowd navigation. We provide experimental insights and lessons learned for algorithmic and experimental design for social robot navigation.
Video

BibTeX
@article{mavrogiannis2022socialmomentum-thri,
  title  = {Social Momentum: Design and evaluation of a framework for socially competent robot navigation},
  author = {Christoforos Mavrogiannis and Patrícia Alves-Oliveira and Wil Thomason and Ross Knepper},
  journal = {ACM Transactions on Human-Robot Interaction},
  year   = {2022}
}Lab members