
IROS '23
From crowd motion prediction to robot navigation in crowds
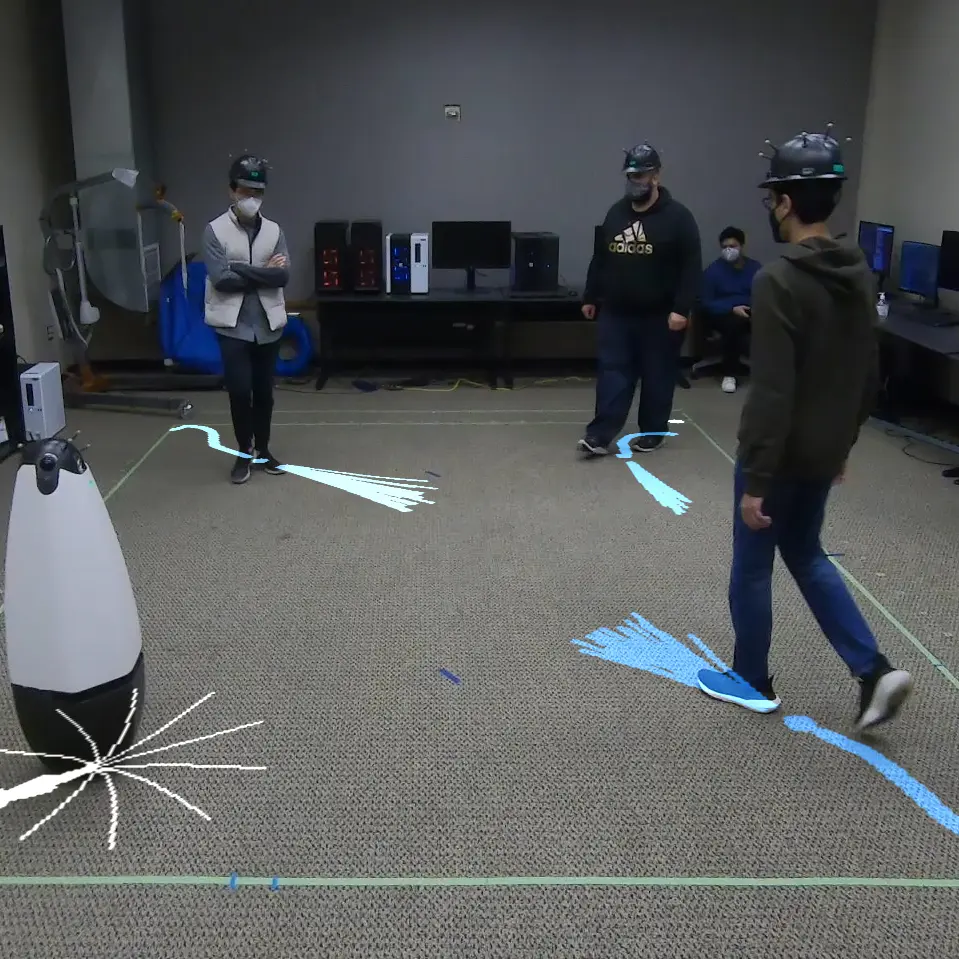
We investigate the transfer of state-of-the-art human motion prediction models to the crowd navigation performance of a mobile robot.
Video

BibTeX
@inproceedings{poddar2023pred2nav,
  title  = {From crowd motion prediction to robot navigation in crowds},
  author = {Sriyash Poddar and Christoforos Mavrogiannis and Siddhartha Srinivasa},
  booktitle = {Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year   = {2023}
}Lab members