thefluentroboticslab
people robots research videos

Videos

Our YouTube channel

ICRA 2026

Bi3: A Biplatform, Bicultural, Biperson Dataset for Social Robot Navigation

RA-L 2026

ReloPush-BOSS: Optimization-guided Nonmonotone Rearrangement Planning for a Car-like Robot Pusher

HRI 2026

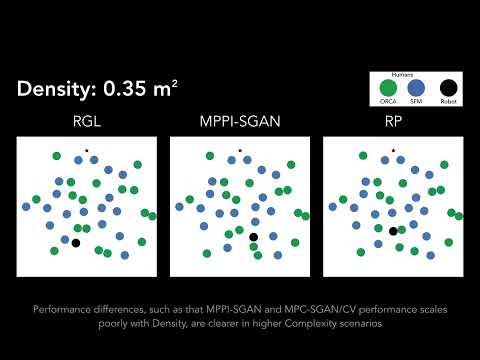
How Human Motion Prediction Quality Shapes Social Robot Navigation Performance in Constrained Spaces

LBR, HRI 2026

Rethinking Legibility in Social Robot Navigation: Impact of Intent Representation and Human Attention

Arts in Robotics, ICRA 2025

From A to Ω: Pixel Art with a Mobile Robot

HRI 2025

Implicit Communication in Human-Robot Collaborative Transport

ICRA 2025

ReloPush: Multi-object Rearrangement in Confined Spaces with a Nonholonomic Mobile Robot Pusher

RA-L/ICRA 2025

Characterizing the Complexity of Social Robot Navigation Scenarios

RSS 2024

HOUND: A Low-Cost Platform for aggressive off-road autonomy research

IROS 2023

From crowd motion prediction to robot navigation in crowds

IROS 2023

Multirobot push-based rearrangement planning

RA-L/ICRA 2023

Crowd navigation via topological invariance

ICRA 2022

Analyzing Multiagent Interactions in Traffic Scenes via Topological Braids

T-HRI 2022

Crowd navigation study at Cornell (N=105)

HRI 2019

HRI 2022

Kuri navigating the UW hallways

IROS 2022

In-hand manipulation via proximity sensing

IJRR 2024

Electrostatic braking for dexterous manipulation

IROS 2020

Telemanipulation with Chopsticks

tech report 2019

MuSHR: The UW open-source robot racecar

IROS 2015

OpenBionics prosthetic hands

IROS 2014

OpenBionics robotic hands

Department of Robotics, University of Michigan

© 2023–∞ Fluent Robotics Lab GitHub YouTube LinkedIn Twitter